
AccessoriesAgiBot
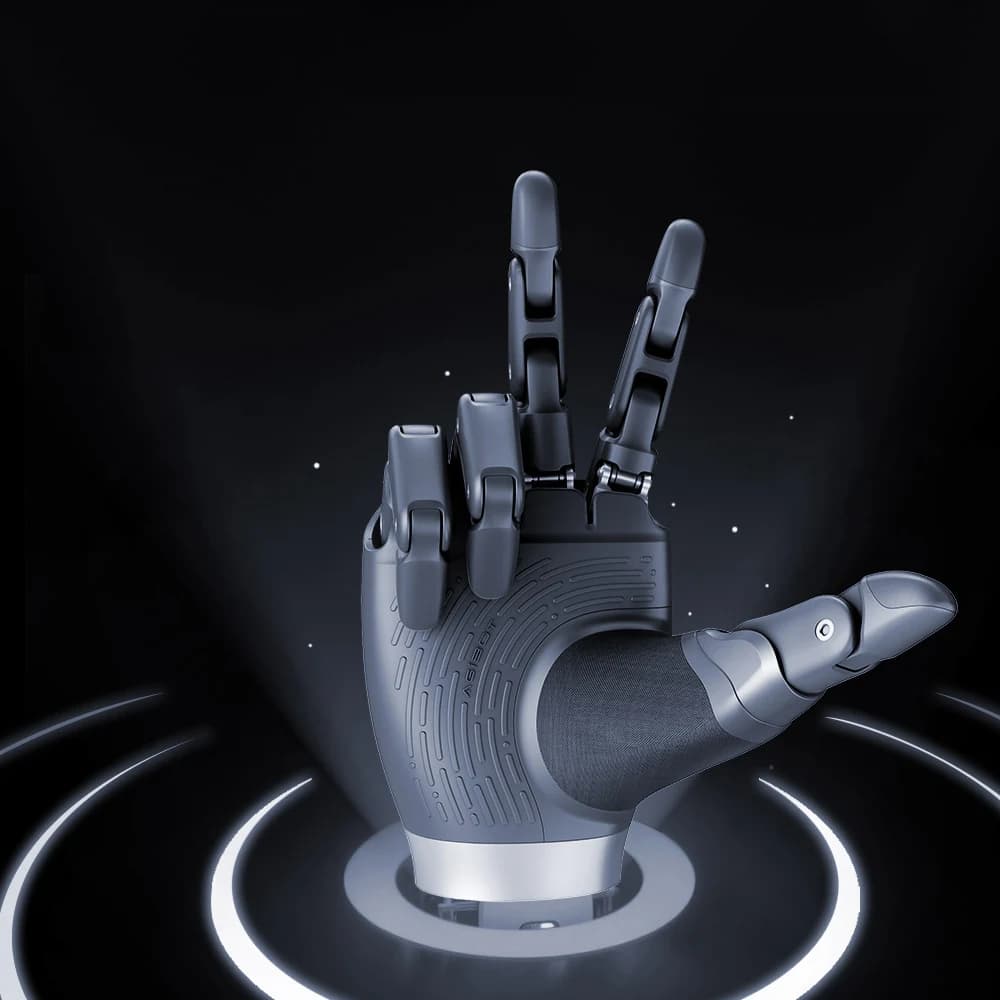
AgiBot OmniHand Pro dexterous hand
A 750 g dexterous hand with 19 degrees of freedom, 20 N fingertip force and over 150 tactile points. Optional accessory for AgiBot robots.
Price
Request a quote
| Specification | OmniHand 3 Ultra-M |
|---|---|
| Active degrees of freedom | 20 |
| Weight | 630 g |
| Size | 189.5 × 88.5 × 40 mm |
| Actuation | Direct drive at every joint |
| Repeatability | ±0.2 mm |
| Opening or closing time | 0.3 s |
| Payload | 3 kg stable grasp, 8 kg lifting |
| Fingertip tactile sensor | Vision-based, 3D distributed force and 6D resultant, 0–30 N, 0.005 N resolution, 0.04 mm spatial resolution, 0.08 mm deformation accuracy |
| Palm tactile sensor | 300 points, 3D force, 0.1 N resolution |
| Communication | CAN FD, RS485 or EtherCAT |
| Reliability | 500,000 validated cycles, 40–45 °C surface under continuous load |
| SDK | Python and C++ |
Similar or complementary products for AgiBot OmniHand 3 Ultra-M dexterous hand
A 750 g dexterous hand with 19 degrees of freedom, 20 N fingertip force and over 150 tactile points. Optional accessory for AgiBot robots.
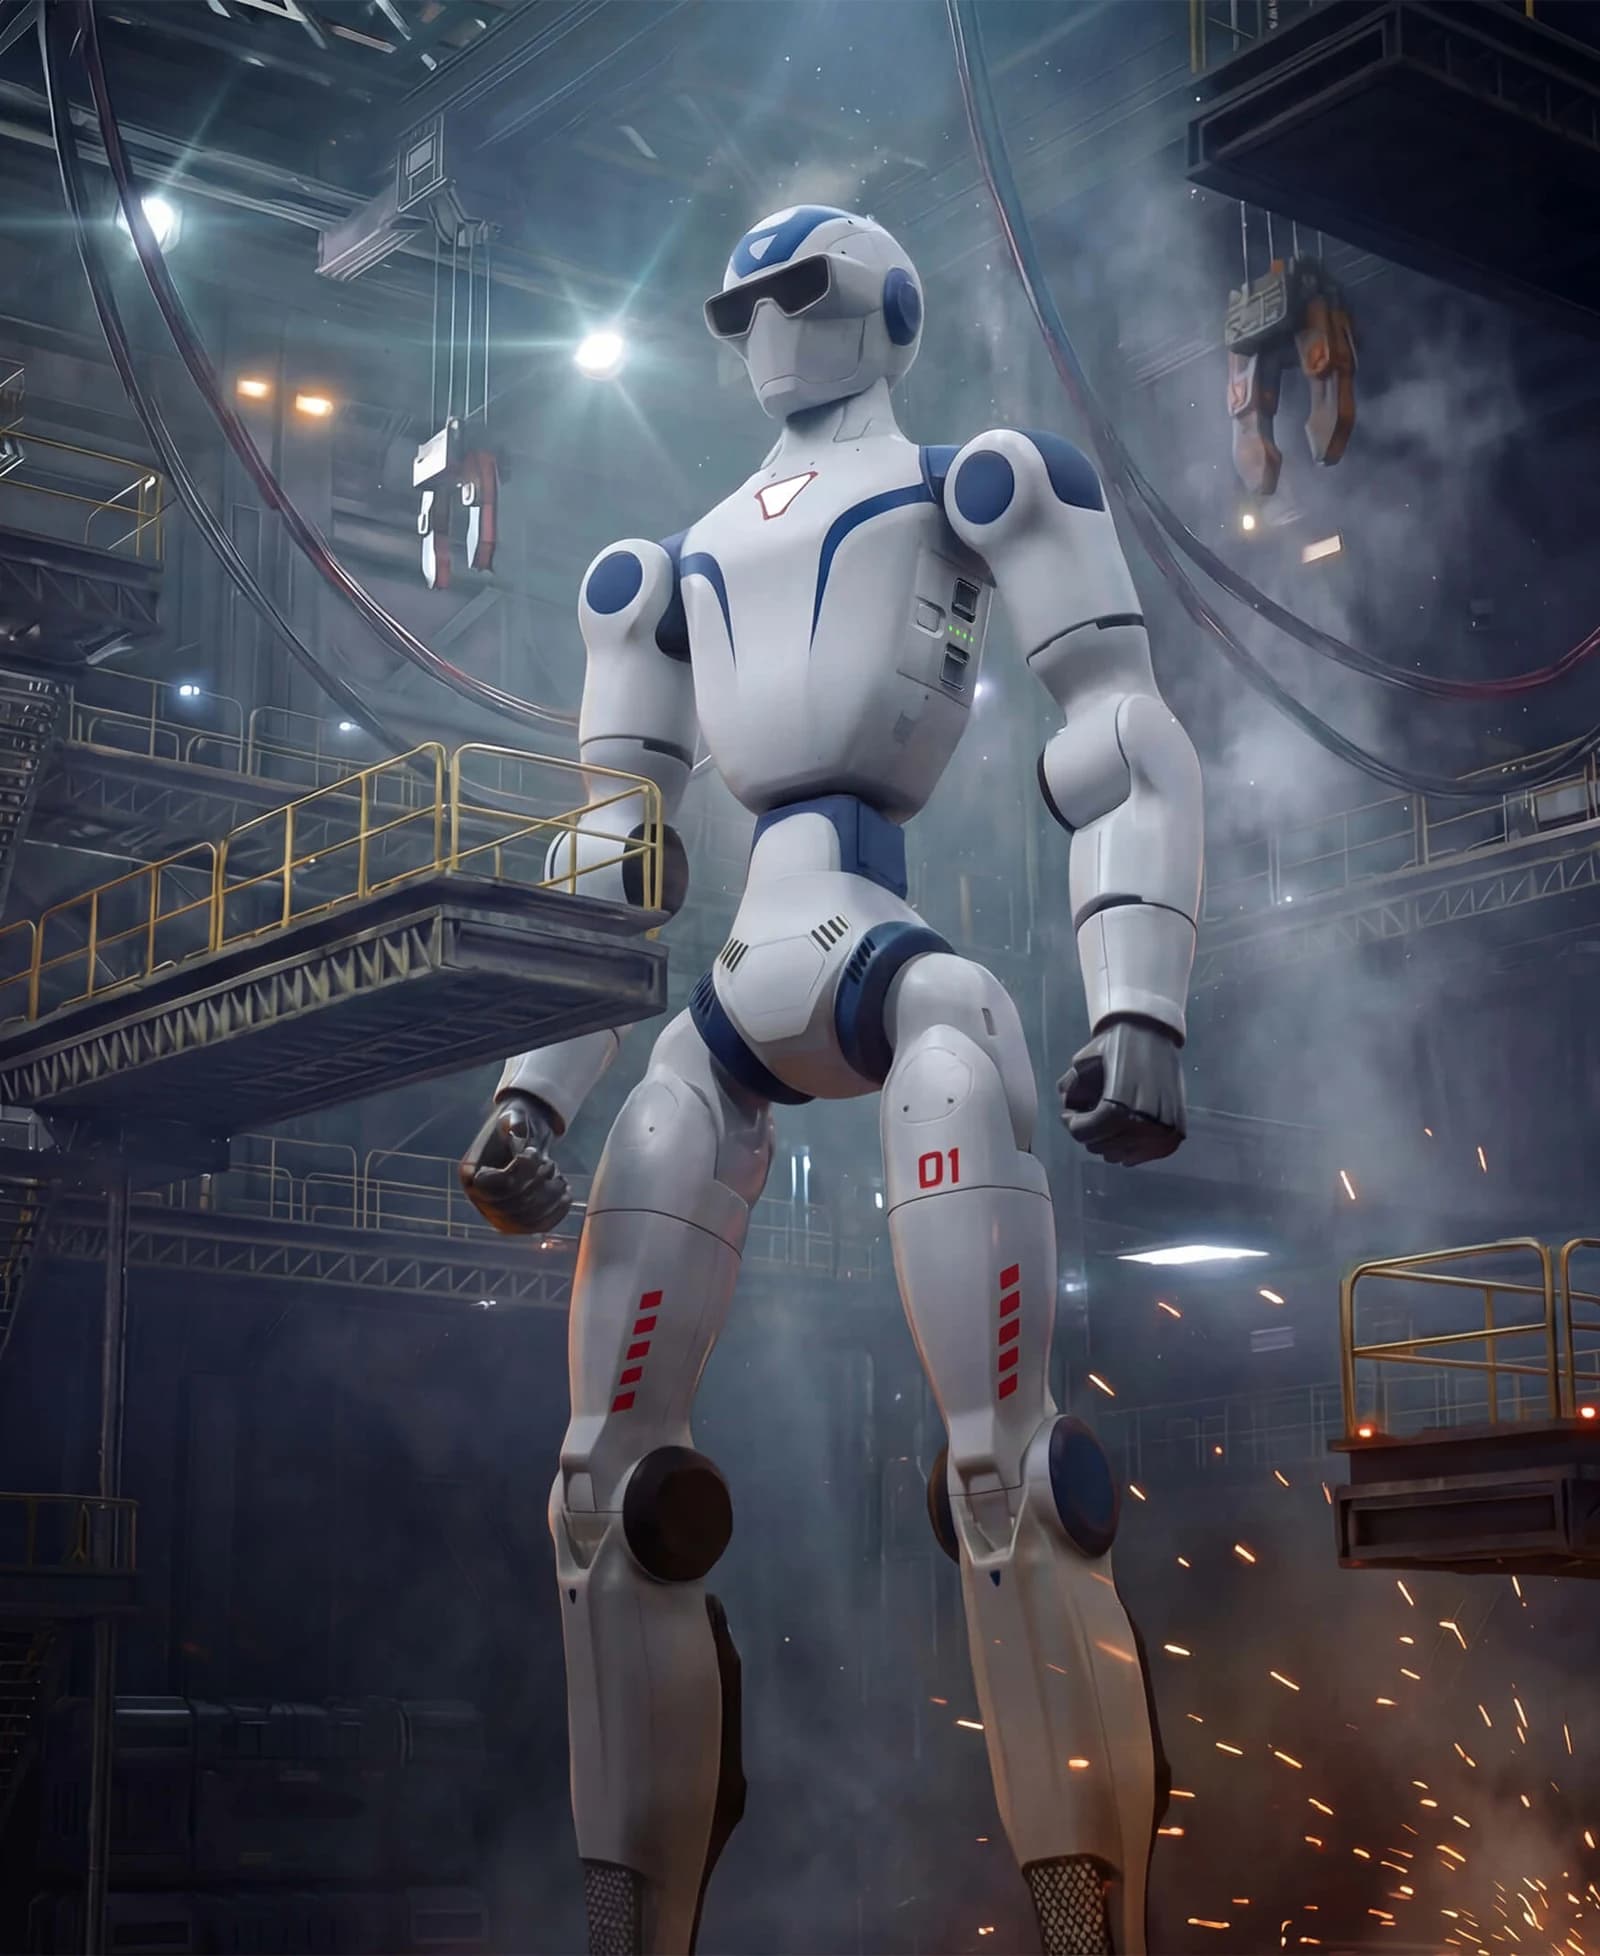
Compact biped humanoid, 123 cm and 29 kg, with a built-in multimodal model for voice and vision. For demos, events and education.

Full-size biped humanoid, 180 cm and 47 kg, with 3D LiDAR and a walking speed of 3.3 m/s as declared by the manufacturer. For locomotion research.
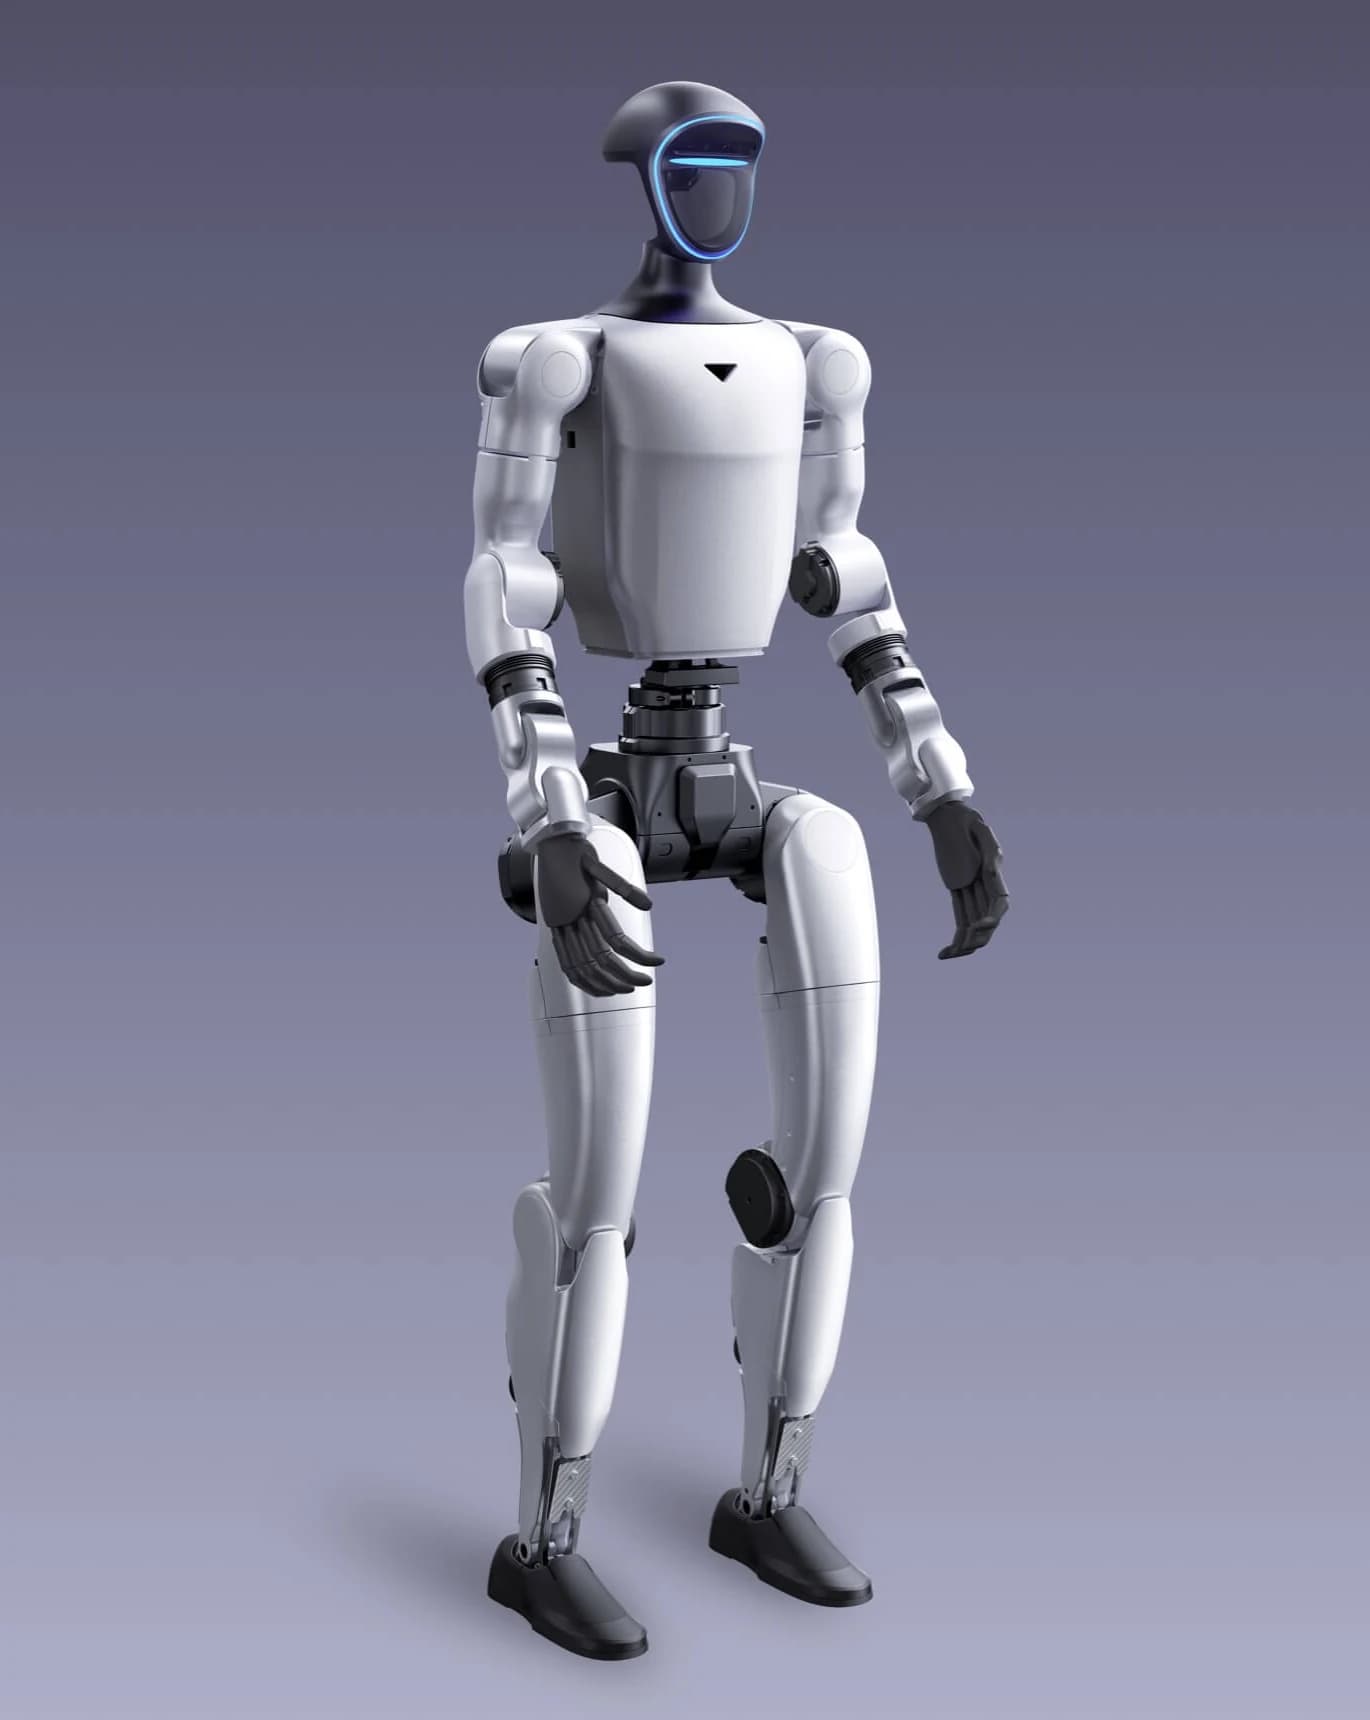
Compact foldable humanoid, 132 cm and 35 kg, with 3D LiDAR and a depth camera. G1 EDU adds secondary development and Dex3-1 hands.